Custom Parameters 2
Select Technology Parameters and choose Laser Technology to view/edit Custom parameters 2.
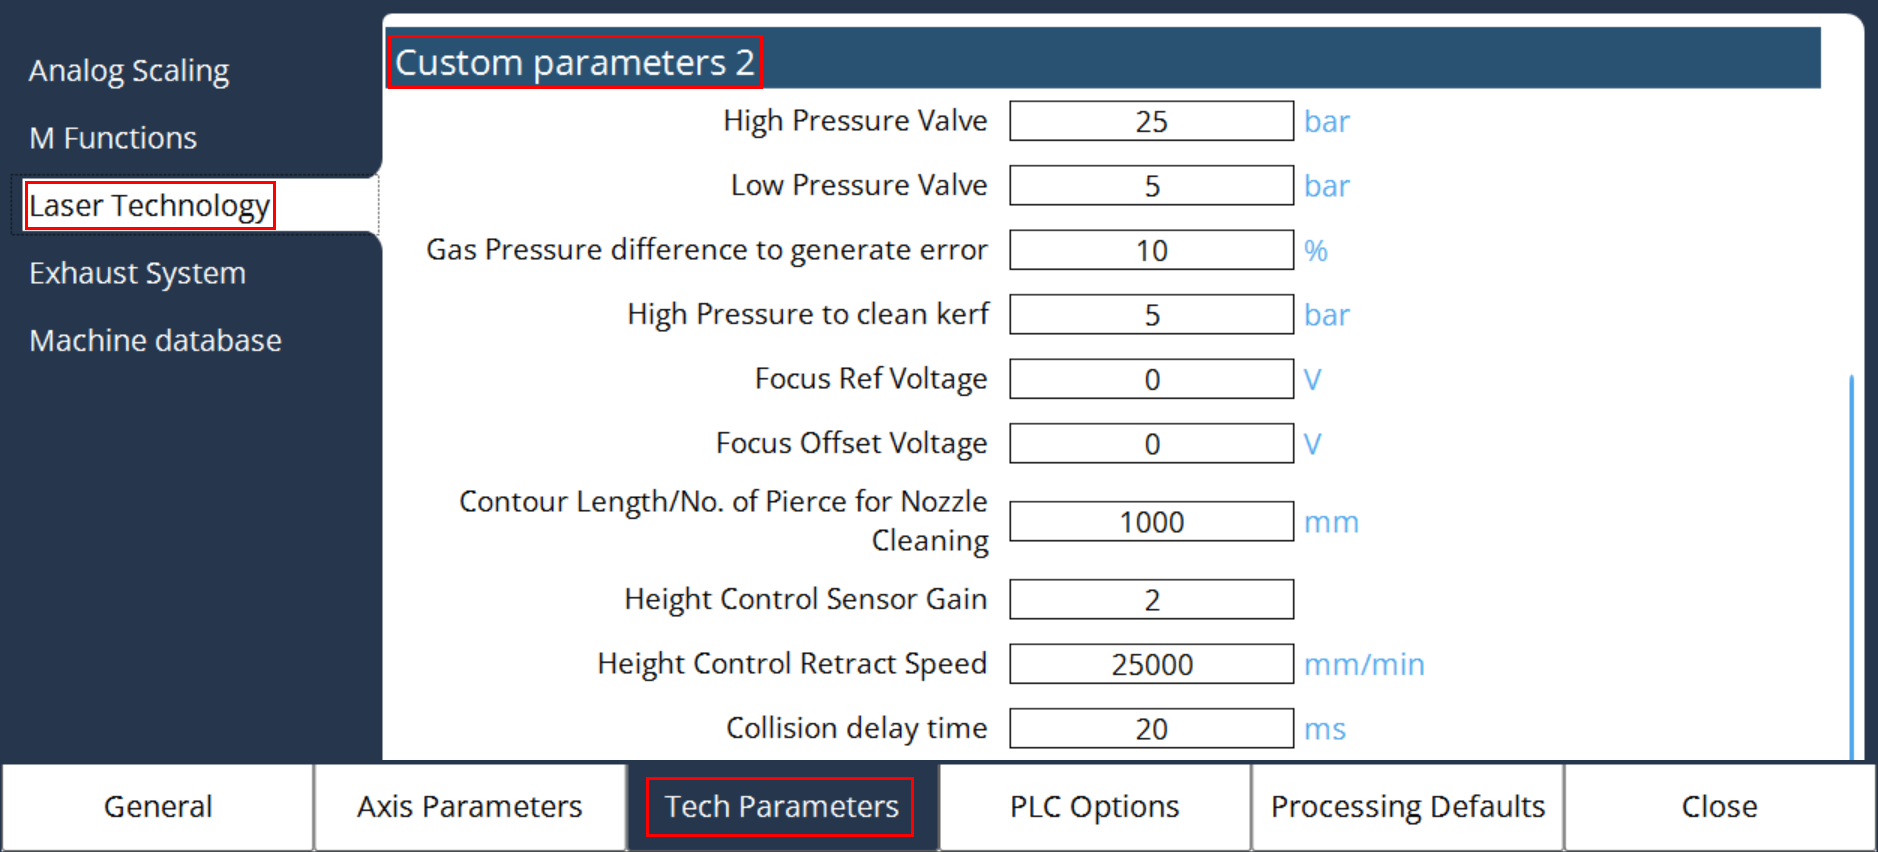
Custom parameters 2 contains 10 entries which are stored one to one in the parameter field from P770-P779 and can be used there arbitrarily.
High Pressure Valve (P770)
This is the maximum value of Pressure in Bar controlled by High pressure valve.
Low Pressure Valve (P771)
This is the maximum value of Pressure in Bar controlled by Low pressure valve. (Gas Type - O2LowPres)
Gas Pressure difference to generate error (P772)
This is the Pressure difference value between Set & Actual in %, to generate the Pressure error. For ex: If P772=10%, then difference between set & actual pressure is > 10%, then the error.
High Pressure to clean kerf (P773)
This is the maximum pressure value to clean the kerf at the end of piercing to clear the molten lava formed on top of the material.
Focus Ref Voltage/Focal Cfg for ProCutter2.0 (P774)
This parameter assigns 2 modes of values depends on the Cutting head type selected in the PLC Options.
-
Precitec Auto Focus Head - the Parameter corresponds to Focus Ref Voltage in Volts
-
Procutter2.0 EG8050 Head - the Parameter corresponds to Focal configuration as follows:
-
0 - 100/125
-
1 - 100/150
-
2 - 100/175
-
3 - 100/200
-
4 - 75/150
-
Focus Offset Voltage (P775)
This value defines the Focus Offset voltage in Volts for Precitec Auto Focus Head.
Contour Length/No. of Pierce for Nozzle Cleaning (P776)
This parameter assigns 2 modes of values depends on the Auto Nozzle clean option selected in PLC options.
-
Auto Nozzle clean based on Contour Length - This parameter corresponds to Contour Length in mm
-
Auto Nozzle clean based on No. of Pierce - This parameter corresponds to No. of Pierce in counts
Height Control Sensor Gain (P777)
This is the Proportional amplification factor of the distance control [m/min/mm].
Height Control Retract Speed (P778)
This value defines the maximum retract speed of height control axis.
Collision delay time (P779)
This is the wait time to react to Tip touch signal from the height control sensor. The reaction will be immediate stop of all the axis with high deceleration and jerk.